Category: Robotics
-
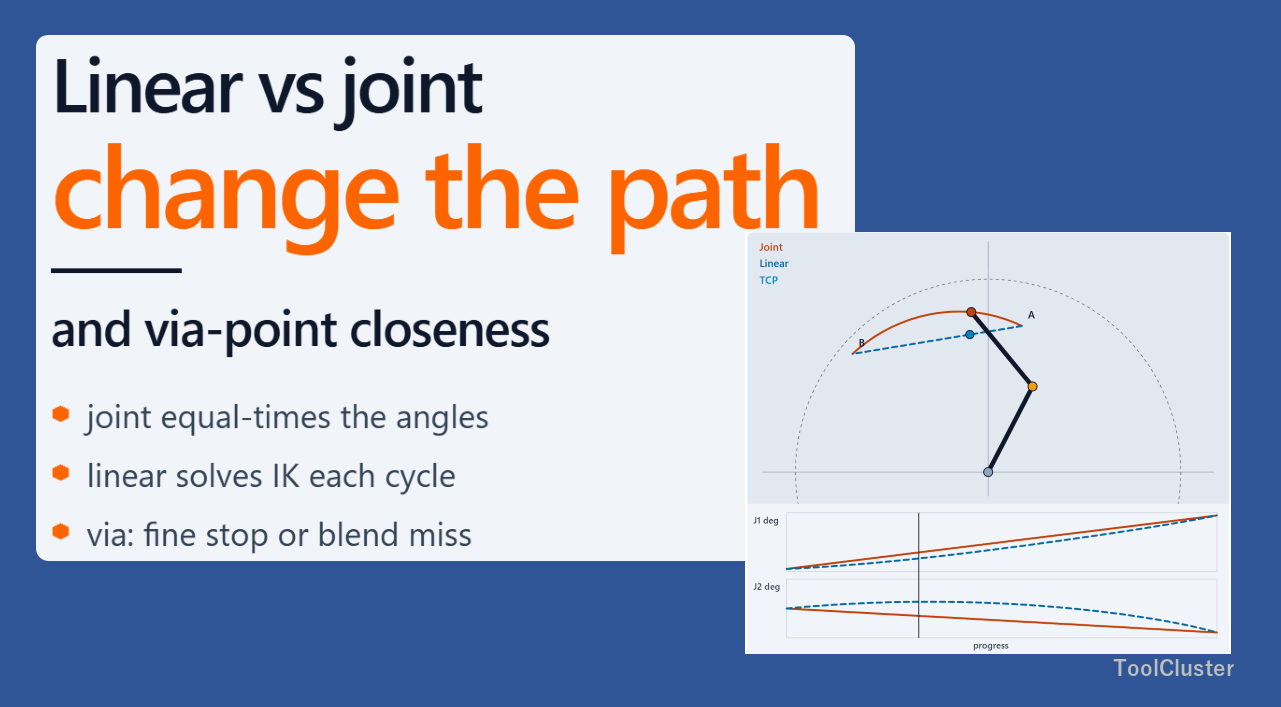
Why TCP Linear and Joint Interpolation Change the Path and Via-Point Closeness — Animated Diagrams
The same two points still give different TCP paths under joint versus linear interpolation. Putting the tool on a straight line means converting back to joint angles every cycle. Speed also cuts path accuracy, and closeness at a via point is fine positioning versus blending. Command names are mapped only…
-
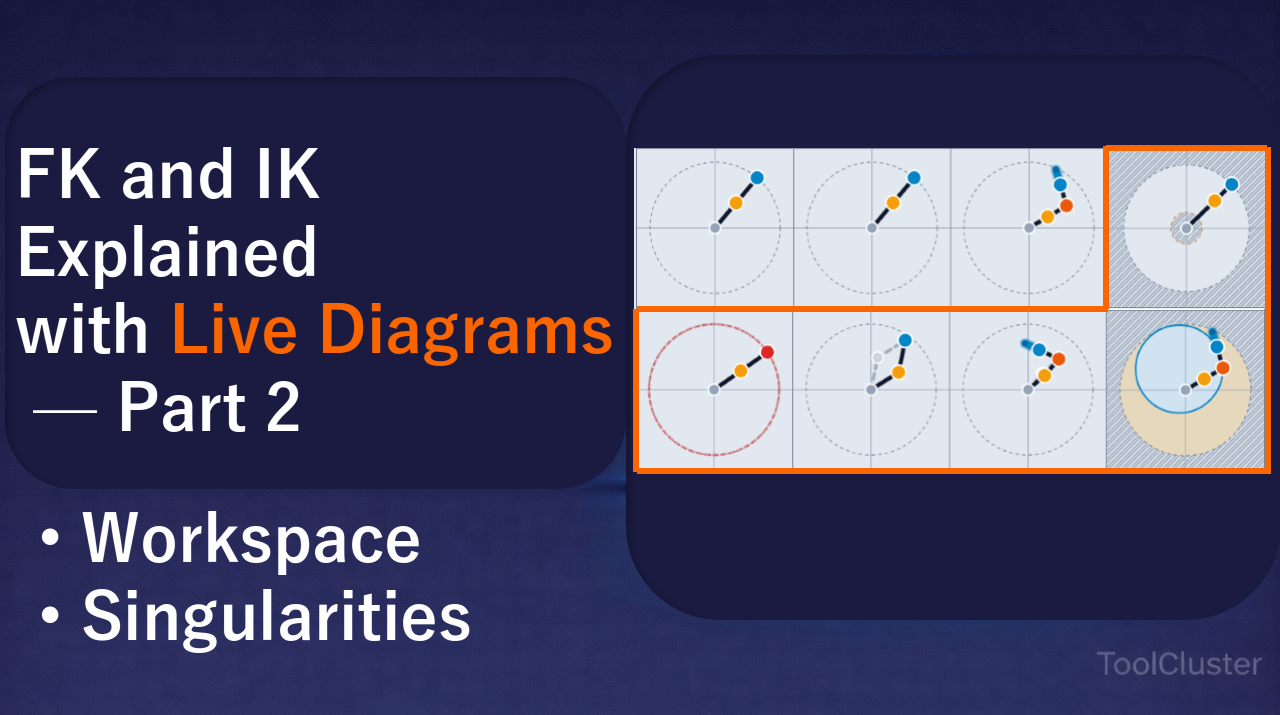
Forward and Inverse Kinematics Explained with Live Diagrams (2): Workspace and Singularities
Where a planar arm can and cannot reach, where its two solutions collapse into one, and how much reach you give up once you also fix the orientation of the tip — explained with diagrams you can drag.
-
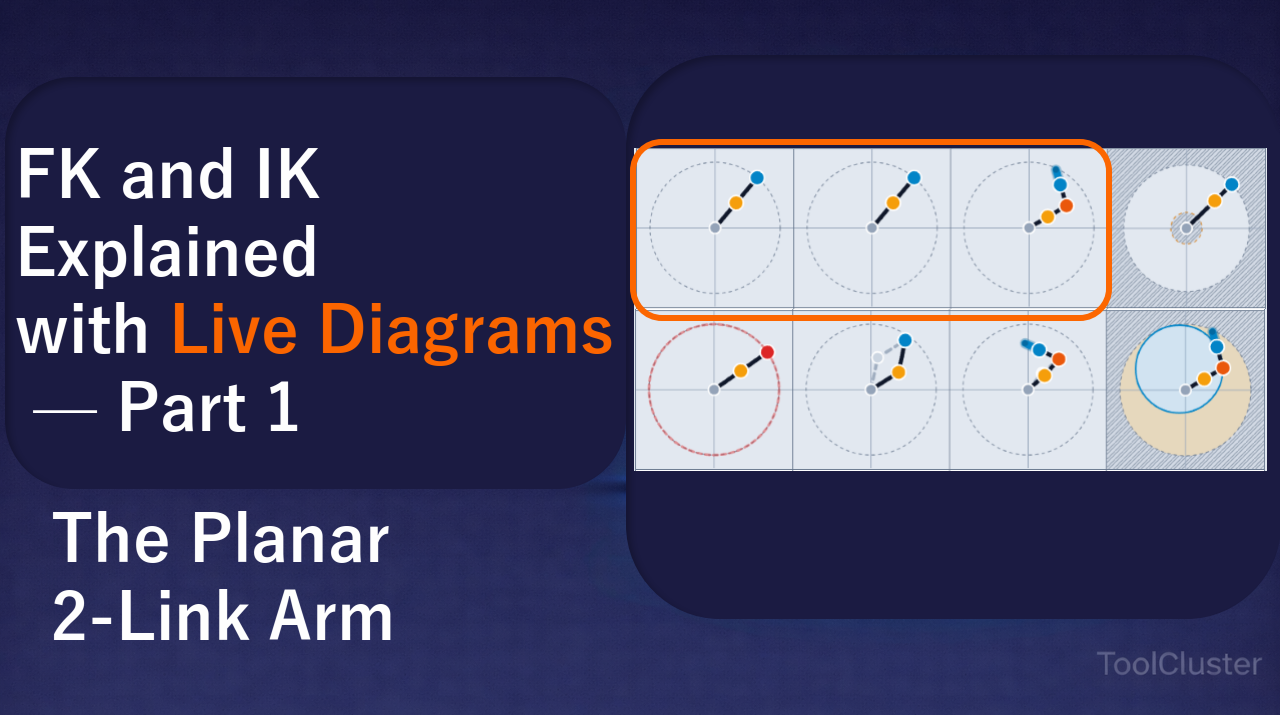
Forward and Inverse Kinematics Explained with Live Diagrams (1): The Planar 2-Link Arm
Forward kinematics turns joint angles into a tip position, and inverse kinematics goes back the other way. Both are explained here with a planar arm you can drag: why the forward direction has exactly one answer, why the inverse one has two, and what a third link buys you.